A wise executive and investor told me years' ago "I would never invest in a company unless I knew the leadership - personally." I've steadfastly followed that advice over the years and have not invested in individual companies for that very reason. So it stands to reason that I don't invest in Tesla as I don't know Elon personally. Nor do I invest in Lucid. And I have a feeling that if my wise old friend knew Elon he would never, under any circumstances, trust him with his money.Tactics (quarterly performance) is critical for winning battles, but strategy (long term planning) wins wars. Ignore either at your peril.
Elon is shifting strategy in a big way. Only time will tell if it’s a brilliant and bold move or a foolhardy pivot.
You are using an out of date browser. It may not display this or other websites correctly.
You should upgrade or use an alternative browser.
You should upgrade or use an alternative browser.
No more Model S/X production
- Thread starter gaskiller
- Start date
- Joined
- Sep 30, 2025
- Messages
- 507
- Reaction score
- 555
- Location
- Silicon Valley adjacent
- Cars
- Gravity GT
- Referral Code
- CA8VVCF7
Yes, but he was asked directly by Kim Java if the Nuro changes were coming to Gravity:Marc Winterhoff mentioned the Nuro version of the Gravity has the Thor processor, so it’s technically feasible.
MW: "The inside, we changed the compute unit from Nvidia Orin X to ... Nvidia Thor.
KJ: "So, are any of those changes going into the customer-facing vehicles as well?
MW: "No. We have a different path."
And unfortunately, the video cuts before he describes that different path.
Then for the Nuro thing they have 4 Thors, plus rear LiDAR plus front and rear corner cameras. Heck, at 7 minutes in we see that the front-facing LiDAR is a completely different unit than on standard Gravitys. Plus side repeater cameras.
MW: "For the Gravity customer, you will get in the next couple of months, hands-free driving in the Gravity, which is actually still based on our own technology, not anything from what Jensen has announced. By the end of the year, the plan is to provide what is called "L2++," which means point-to-point, including inner cities hands off, but eyes on, driving. By end of this year. "
He then talks about L3 and L4 taking up to 2029 to happen, but "and that will come first in our midsize plaform - that will be the first that we enable for L3 and L4."
-----
My take is that we'll be lucky to get L2++ working in the Gravity, and even that is dependent on Nvidia back porting the Alpamayo to Orin X.
I do also think Winterhoff doesn't understand what L3 and L4 actually are, and Nuro needing to outfit the Gravity like Waymo outfits the iPace seems behind the times to me, and locks out personally owned Gravitys from ever achieving that. But, that could be just me.
- Joined
- May 19, 2025
- Messages
- 494
- Reaction score
- 636
- Cars
- BMW X1
Given all the design decisions he himself pushed, I'm calling it and say it'll flop. Tesla didn't get its success because of him. Tesla succeeded despite him.Tactics (quarterly performance) is critical for winning battles, but strategy (long term planning) wins wars. Ignore either at your peril.
Elon is shifting strategy in a big way. Only time will tell if it’s a brilliant and bold move or a foolhardy pivot.
Besides, especially on automotive projects, the steps in the project's cycle such as designing, simulating, prototyping, iterating, manufacturing, and all the way to up production, quarters mean nothing other than to appease shareholders. I'm a shareholder myself and even I get annoyed with how insufferable the shareholder questions become during the quarterly meetings.
Back to getting on topic of the thread, I think it's a mis-step to kill the Model S and X programs. Part of the point of expensive models is to provide a testbed for new tech and to figure out the growing pains of scaling up the manufacturing of said tech. Then, take those learning to more affordable models.
- Joined
- Sep 30, 2025
- Messages
- 507
- Reaction score
- 555
- Location
- Silicon Valley adjacent
- Cars
- Gravity GT
- Referral Code
- CA8VVCF7
Earth is supposed to be a mid-priced car, and throwing all those sensors, even at today's reduced prices compared to a few years ago, will add cost to the vehicle. Plus, Winterhoof says Earth has fewer parts than Model Y, so adding a bunch of cameras and a bunch of LiDARs is the other way. The way Winterhoof was talking in the Kim Java video I just posted, has him giving dates of 2029 and 2030 for L3 and L4, so that's not Earth, at least not Earth Gen-1. Happy to be proven wrong, though.Given we have no idea what the car looks like, it very well may not. It’s possible they integrate components elsewhere. The reason you see the “halo” on gravity and in waymo is explicitly because they are retrofitting hardware to the vehicle. That isn't the case with Earth.
- Joined
- Sep 30, 2025
- Messages
- 507
- Reaction score
- 555
- Location
- Silicon Valley adjacent
- Cars
- Gravity GT
- Referral Code
- CA8VVCF7
I went to a small entrepreneurial group gathering a year ago, where the speaker was Mercedes' CEO Ola Källenius. He specifically told us: "Our old paradigm for new technology was start at S Class and trickle down' now different - we're doing things first on the upcoming CLA."Part of the point of expensive models is to provide a testbed for new tech and to figure out the growing pains of scaling up the manufacturing of said tech. Then, take those learning to more affordable models.
- Joined
- Nov 9, 2025
- Messages
- 823
- Reaction score
- 1,273
- Cars
- Model X, XC90, S4, LS460
- Air DE Number
- 1
- Gravity DE Number
- 160
- Referral Code
- 34DTL9L0
Agree, it’s clear that Nuro isn’t coming to the consumer Gravity. We are not going to put that sensor suite on our cars. Besides the sensor suite, though, the only internal change was the upgrade to the Thor processor. This implies technical feasibility for a processor swap. Whether or not Lucid will offer it down the road (or will need too) is a different story.Yes, but he was asked directly by Kim Java if the Nuro changes were coming to Gravity:
MW: "The inside, we changed the compute unit from Nvidia Orin X to ... Nvidia Thor.
KJ: "So, are any of those changes going into the customer-facing vehicles as well?
MW: "No. We have a different path."
And unfortunately, the video cuts before he describes that different path..
That other path is Nvidia. This may be wishful thinking on my part, but nothing else makes sense. I doubt Lucid is in a financial position to develop an entire AI autonomous technology stack on its own.

- Joined
- Jan 2, 2026
- Messages
- 406
- Reaction score
- 631
- Location
- Detroit, Michigan
- Cars
- 2023 Air GT (White)
I got in when the market tanked in 2020. Something about a pandemic. Several of the stocks I was following but hadn't invested in tanked hard, so I swooped in like a vulture and bought up a lot of shares. I bought TSLA at $472 ($31.49 after the splits) and NVDA at $124 ($12.45 after the split). There were times with both where my finger was on the mouse, ready to click away but I white-knuckled my way through it.……. Don’t see that happening in the foreseeable future… But then again anything is possible with changes in the economy
i’ve owned it for last 13 years ( haven’t sold a share) if you’ve been in it for a while, you know it’s not always an easy hold lol.
i’ve been in and out of lucid about eight times made a SOLID move when it was a spac.
Part of my retirement job
Got back in when it dropped down near $1.50
Elon lives of the US GOV- his companies got 38 billion dollars in subsidies. Just a hypocritical jackass in my books.A wise executive and investor told me years' ago "I would never invest in a company unless I knew the leadership - personally." I've steadfastly followed that advice over the years and have not invested in individual companies for that very reason. So it stands to reason that I don't invest in Tesla as I don't know Elon personally. Nor do I invest in Lucid. And I have a feeling that if my wise old friend knew Elon he would never, under any circumstances, trust him with his money.
- Joined
- Sep 30, 2025
- Messages
- 507
- Reaction score
- 555
- Location
- Silicon Valley adjacent
- Cars
- Gravity GT
- Referral Code
- CA8VVCF7
There are so many good and valid reasons to dislike or even hate Musk, it saddens me when people either mis-state the data or are missing the real data.Elon lives of the US GOV- his companies got 38 billion dollars in subsidies. Just a hypocritical jackass in my books.
There's no doubt that Elon's DOGE efforts were indeed a disgrace, and his efforts to reduce government spending when his companies benefit from government spending were indeed hypocritical (and immoral/unethical and hurt people badly), but his companies did not get "38 billion dollars in subsidies."
The $38B number comes from a Washington Post article (link) from early last year, but that total also includes contracts, loans (paid back with interest), and GHG credits (which Lucid also got, and are paid by other companies, not taxpayers). And by far, contracts to Space-X are the largest share of that total. I suppose we could have had the US government continue to award space launch contracts to ULA (Boeing and Lockheed-Martin co-own that), which used Russian rocket engines almost exclusively and cost the taxpayers a lot more per launch, but that would be like biting your nose to spite your face.
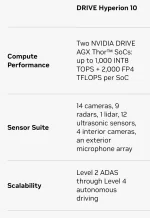
We know exactly what the Earth will be equipped with because of Lucid's partnership with Nvidia. They're using Nvidia's standardized sensor suite in Hyperion 10. See photo/link below.Earth is supposed to be a mid-priced car, and throwing all those sensors, even at today's reduced prices compared to a few years ago, will add cost to the vehicle. Plus, Winterhoof says Earth has fewer parts than Model Y, so adding a bunch of cameras and a bunch of LiDARs is the other way. The way Winterhoof was talking in the Kim Java video I just posted, has him giving dates of 2029 and 2030 for L3 and L4, so that's not Earth, at least not Earth Gen-1. Happy to be proven wrong, though.
Updated link: https://nvidianews.nvidia.com/news/nvidia-uber-robotaxi
Attachments

I think $50K is planned for entry point. They will probably top out much higher, if you want DDP, SSP, etc. That 50K entry point leaves alot of room for different levels of ADAS.
Also the MB CLA that is said to be point-to-point ready, which was demoed by a host of journalists, is based on the same hardware as the Gravity. See the reference to Orin in the link below.
https://qz.com/nvidia-autonomous-vehicles-demo-drive-waymo-tesla
https://qz.com/nvidia-autonomous-vehicles-demo-drive-waymo-tesla
Forgot which of Lucid's executives said it, but they confirmed all midsize vehicles will be delivered with full L4 hardware suite and it will be a subscription-based model for ADAS capabilities.I think $50K is planned for entry point. They will probably top out much higher, if you want DDP, SSP, etc. That 50K entry point leaves alot of room for different levels of ADAS.
- Joined
- Sep 30, 2025
- Messages
- 507
- Reaction score
- 555
- Location
- Silicon Valley adjacent
- Cars
- Gravity GT
- Referral Code
- CA8VVCF7
We know exactly what the Earth will be equipped with because of Lucid's partnership with Nvidia. They're using Nvidia's standardized sensor suite in Hyperion 10. See photo/link below.
From your link:
So, "exactly" isn't necessarily true. It's a "reference architecture," enabling OEMs to customize. Lucid could decide to use a different LiDAR vendor and/or add more sensors, or even subtract some. In the interview above, Winteroff talked about a 2029-2030 3/L4 timeframe, and by then Thor will have been replaced with a generation or two later chip. Lucid may wish to reduce their efforts and stick closely to the reference setup, though.DRIVE AGX Hyperion 10 is modular and customizable, allowing manufacturers and AV developers to tailor it to their unique requirements.
When I met the Mercedes CEO, he told us that the CLA will get the Thor chip, although the first car shipments will have the Orin. The target for the CLA is L2, not L3/L4.
Point-to-point wasn't actually demoed. For instance, in Everyday Chris's video, the car had to be manually driven out of a street parking spot. Like with Tesla, we have to be careful about what is being promised versus what is actually working today.Also the MB CLA that is said to be point-to-point ready, which was demoed by a host of journalists, is based on the same hardware as the Gravity. See the reference to Orin in the link below.
Agreed on all points here. The simplest path forward for Lucid is to utilize the standard hardware Nvidia is offering, as it's a tried and tested system. Given Lucid's limited cash and ADAS timeline, it wouldn't make sense for them to spend time and money doing R&D to make their own custom sensor suite.From your link:
So, "exactly" isn't necessarily true. It's a "reference architecture," enabling OEMs to customize. Lucid could decide to use a different LiDAR vendor and/or add more sensors, or even subtract some. In the interview above, Winteroff talked about a 2029-2030 3/L4 timeframe, and by then Thor will have been replaced with a generation or two later chip. Lucid may wish to reduce their efforts and stick closely to the reference setup, though.
Sure, by the time L4 is available a newer chip may be in the newest cars, but I think their ADAS timeline (along with other autos) is based on development of software, rather than being limited by hardware.
I thought point-to-point was just getting you from one destination to another using streets? Is parking included?Point-to-point wasn't actually demoed. For instance, in Everyday Chris's video, the car had to be manually driven out of a street parking spot. Like with Tesla, we have to be careful about what is being promised versus what is actually working today.
- Joined
- Nov 9, 2025
- Messages
- 823
- Reaction score
- 1,273
- Cars
- Model X, XC90, S4, LS460
- Air DE Number
- 1
- Gravity DE Number
- 160
- Referral Code
- 34DTL9L0
Yes, Tesla FSD point-to-point includes parking-to-parking. The latest version is pretty impressive and works great most of the time. It’s the failure rate that is holding things back.I thought point-to-point was just getting you from one destination to another using streets? Is parking included?
The question is, is vision-only good enough, or does incorporating radar, ladar, and sonar elevate ADAS capabilities to give a higher level of safety? Personally, it’s one of the factors that went into me choosing the Gravity over a Tesla, as good as Tesla FSD is today. The Gravity has sensors beyond just vision and I believe that will make the system better and safer. I’m willing to wait a bit for ADAS software built on a sensor platform that will have a higher chance of keeping me alive.
- Joined
- Jan 2, 2026
- Messages
- 406
- Reaction score
- 631
- Location
- Detroit, Michigan
- Cars
- 2023 Air GT (White)
Several times, today even, my wife has engaged FSD in our garage and had it navigate her to a parking spot at her gym. She just has to tap the screen to choose a parking spot.I thought point-to-point was just getting you from one destination to another using streets? Is parking included?
Yes, Tesla FSD point-to-point includes parking-to-parking. The latest version is pretty impressive and works great most of the time. It’s the failure rate that is holding things back.
The question is, is vision-only good enough, or does incorporating radar, ladar, and sonar elevate ADAS capabilities to give a higher level of safety? Personally, it’s one of the factors that went into me choosing the Gravity over a Tesla, as good as Tesla FSD is today. The Gravity has sensors beyond just vision and I believe that will make the system better and safer. I’m willing to wait a bit for ADAS software built on a sensor platform that will have a higher chance of keeping me alive.

- Joined
- May 1, 2022
- Messages
- 6,499
- Reaction score
- 10,365
- Location
- San Francisco, CA
- Cars
- Air Touring
- Referral Code
- MX1KDTYY
It’s worth noting thus far, unlike many other brands, Lucid has actually hit their entry price number. So I’m confident an actual $49,999 midsize will be sold.I think $50K is planned for entry point. They will probably top out much higher, if you want DDP, SSP, etc. That 50K entry point leaves alot of room for different levels of ADAS.
Whether or not anyone will want that model is another story. But I have every confidence you will be able to drive midsize for that price.
I expect a high-end fully loaded midsize to be somewhere in the $80k range. Depending on how badly Lucid wants to continue to be thought of as a luxury brand. We have zero knowledge of what will be offered as options. I’m holding out hope for similar features to Air, including massage seats, heating and cooling seats and wheel, etc. We’ll see.
I absolutely agree they will offer it at their $50K price point. Just like they did with the Gravity Touring. I think they will also find ways to offer two models/packages (not top hats, but versions within top hats), just like they did with Gravity.It’s worth noting thus far, unlike many other brands, Lucid has actually hit their entry price number. So I’m confident an actual $49,999 midsize will be sold.
Whether or not anyone will want that model is another story. But I have every confidence you will be able to drive midsize for that price.
I expect a high-end fully loaded midsize to be somewhere in the $80k range. Depending on how badly Lucid wants to continue to be thought of as a luxury brand. We have zero knowledge of what will be offered as options. I’m holding out hope for similar features to Air, including massage seats, heating and cooling seats and wheel, etc. We’ll see.
And, I'm good with that. You can get into a Macan Electric for one price, BUT, if you want the cool doodads, ah, that will be another $20-30K. Goes back to letting me decide what I want and how much I'm willing to spend. Freedom of choice. America is a wonderful place to live!