Correct, it only rules out tire traction limitations as an acceleration constraint.Ok, but this doesnt rule out software limiting torque output?
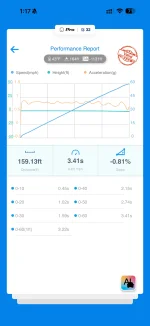
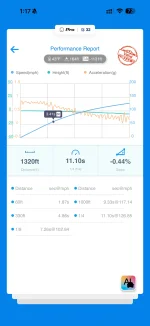
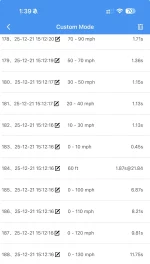
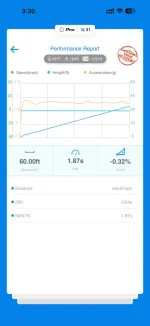
They could be capping max torque or delaying arrival of max torque, which would limit acceleration. For most BEVs, the acceleration is very linear from 0 MPH until around 45-50 MPH. Then the rate of acceleration will start to curve downward more as torque declines while drag continues to increase. You can easily see if Lucid is limiting early torque delivery by a non-linear acceleration graph in the early MPH ranges.