This is a global issue not a 3.4.1 bug.
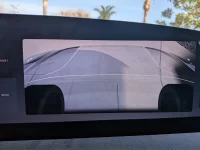
However, with the new 3.4.1 update and transparent views I just did 30+ minutes of experiments trying to pull forward and back up to a line in my driveway to predict location of tires, front bumper or rear bumper. Most of this was done pulling forward or backwards within a 10-15 ft area.
The summary is that the various angles and modes give me ZERO confidence in accurately lining up tires or bumpers precisely with lines on the pavement. The margin of error gets worse if trying to adjust and pull forward or backwards only one foot from a stop/parked position as opposed to adjusting over 10 feet.
I can confidently say that it's impossible to predict where my bumpers will end up relative to that line using the various camera angles or imposed silhouettes in any mode. I could not get my front or rear bumper to line up perfectly with a line with any degree of consistency or confidence.
The error was inches to 2+ feet depending on camera angle/silhouette used and whether I did short range adjustment from a stop or longer range 'pulling in', and also whether i was backing up or pulling forward to a line.
I did not experiment with pulling up to a wall or car, these were exclusively to lines on the concrete. Because of how low the car can be I try not to get too close to those ~4-6" concrete parking stops that are parking lots. These experiments do not inspire confidence that I can judge where my bumper would be relative to such an hazard. I've been trying to learn the boundaries of the car for months and still do not have a grasp (something I have had pathologically-to-the-milimeter understanding of in any prior car).
Can anyone else do some experimenting and report back?
Attachments
Last edited:

